Exploring the Frontiers of Space Robotics
SpaceR is a space robotics research group at SnT, University of Luxembourg, led by Associate Prof. Dr. Miguel Olivares-Mendez , head of the RG,and Assistant Prof. Dr. Carol Martinez-Luna, deputy head. We develop autonomous systems for planetary exploration, in-orbit servicing, multi-modal perception and debris removal — validated in our on-site research facilities.
Research Themes
Planetary Robotics
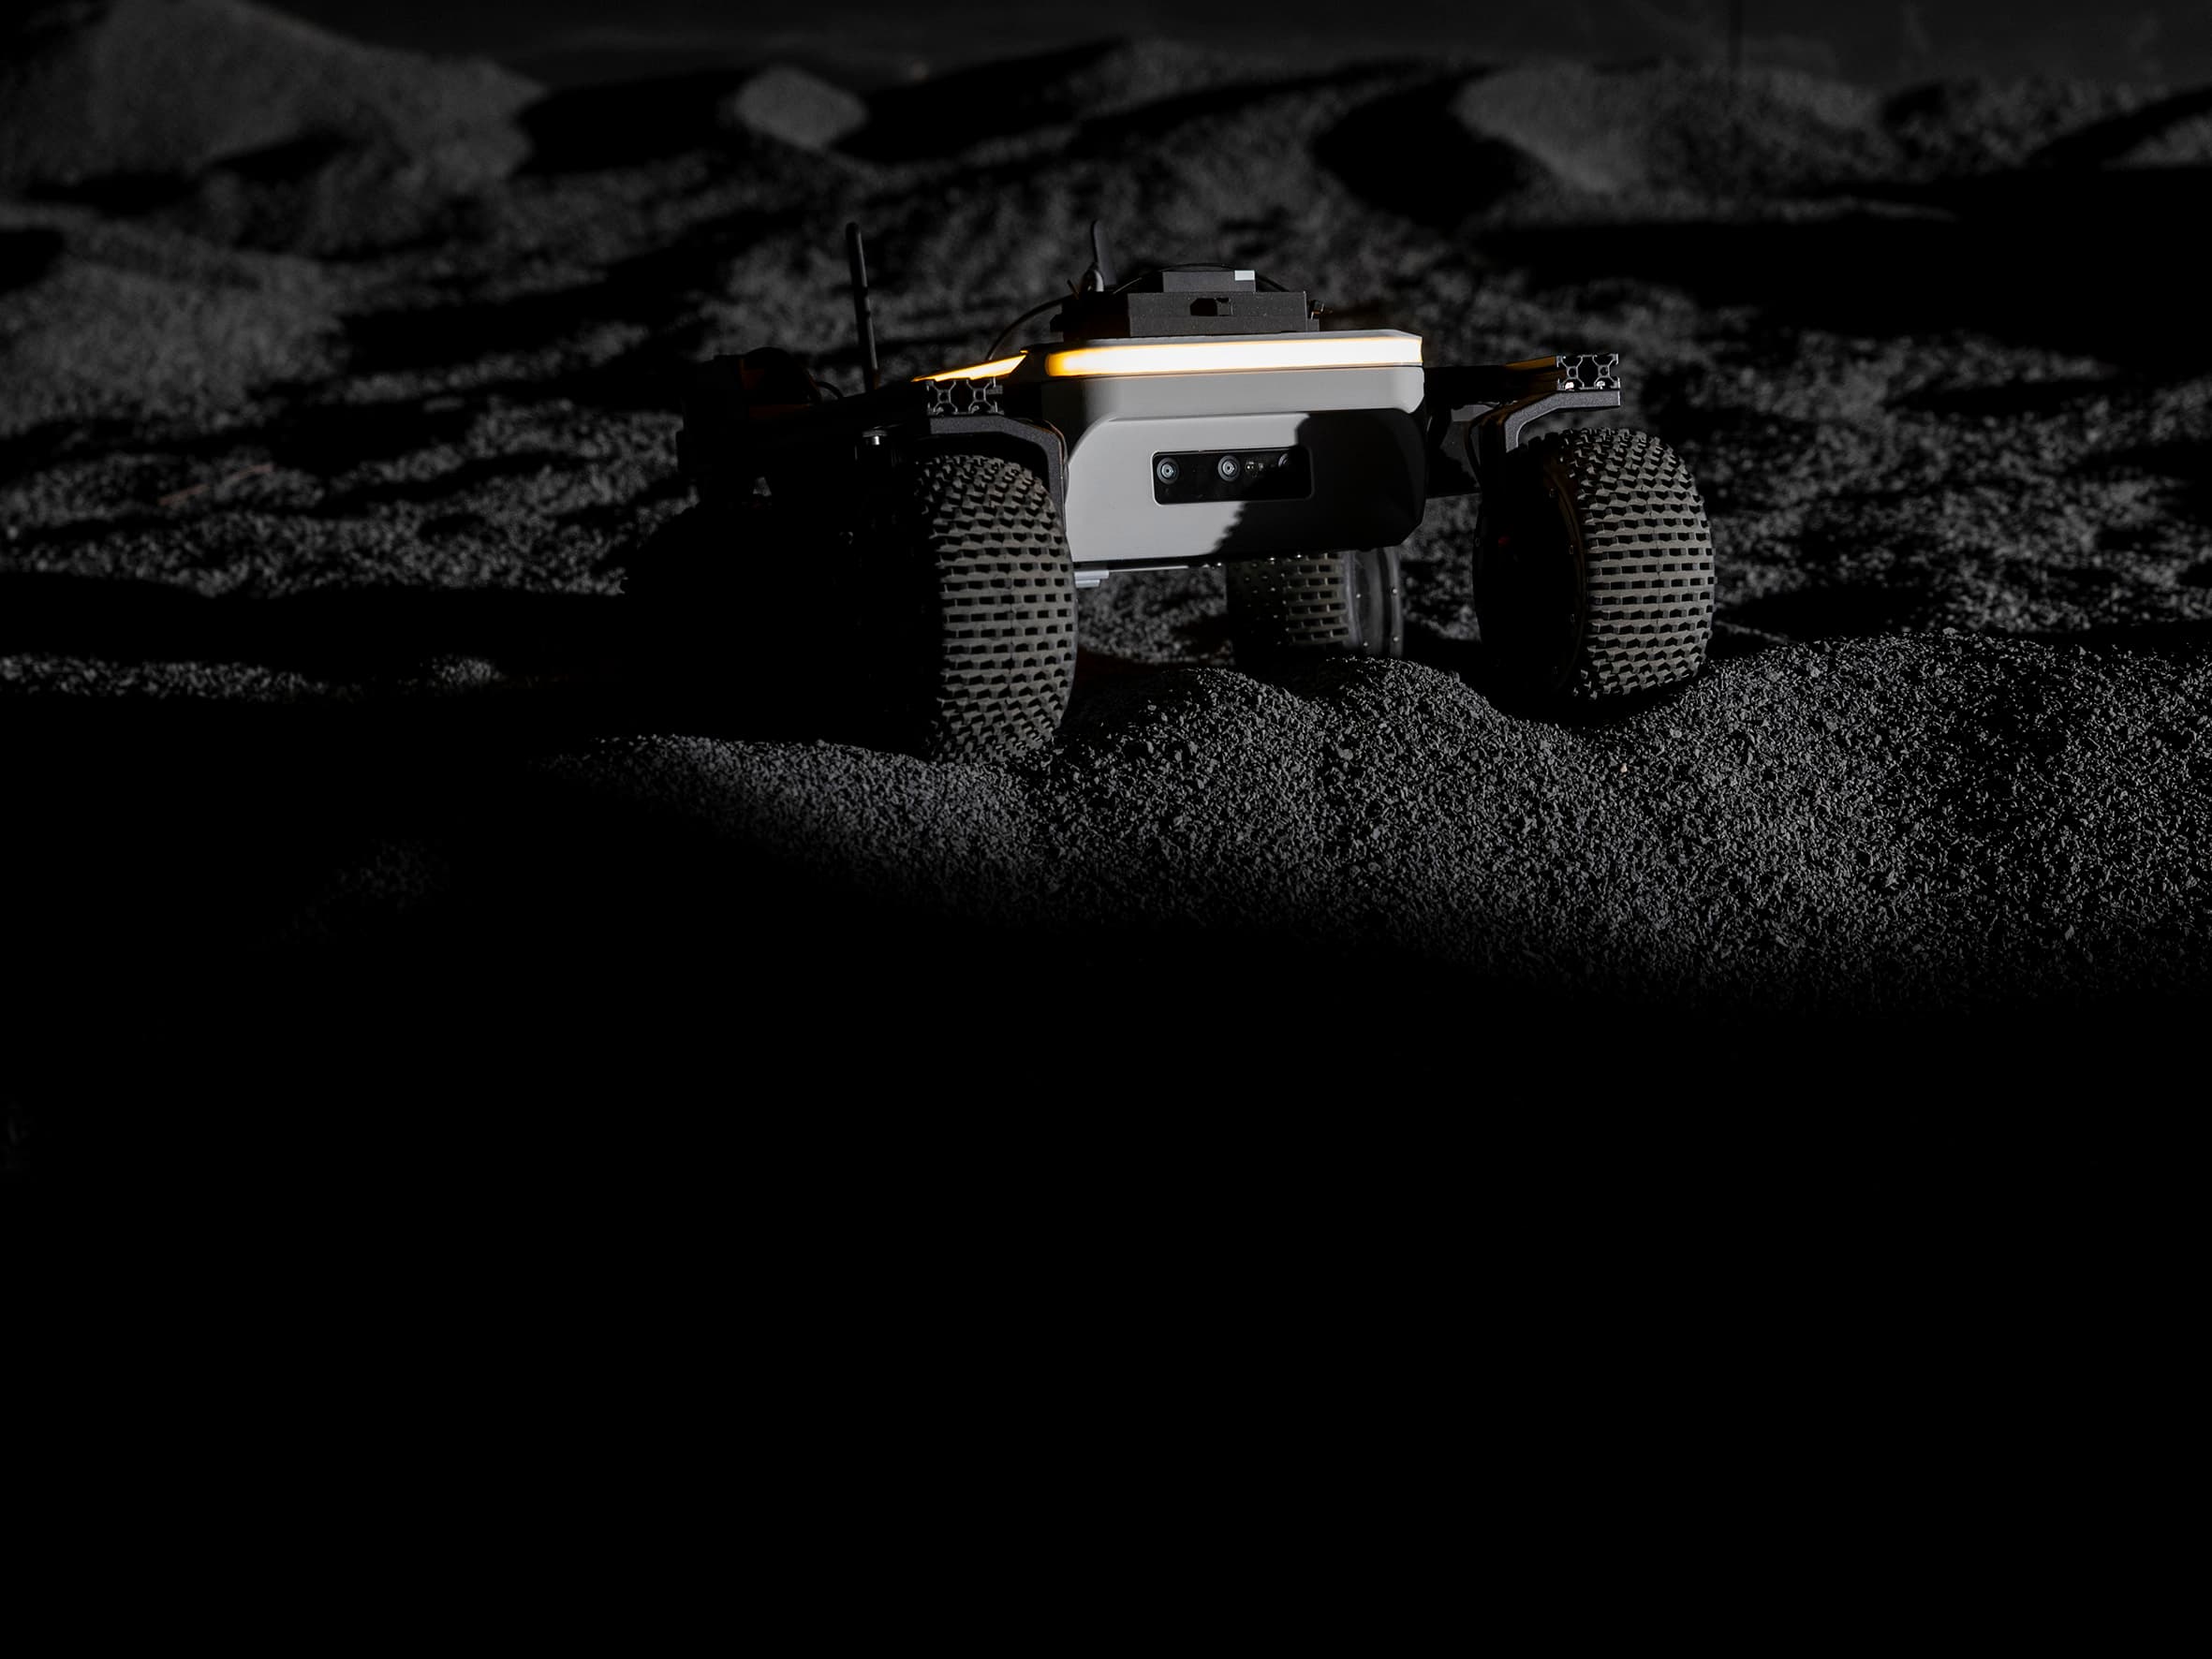
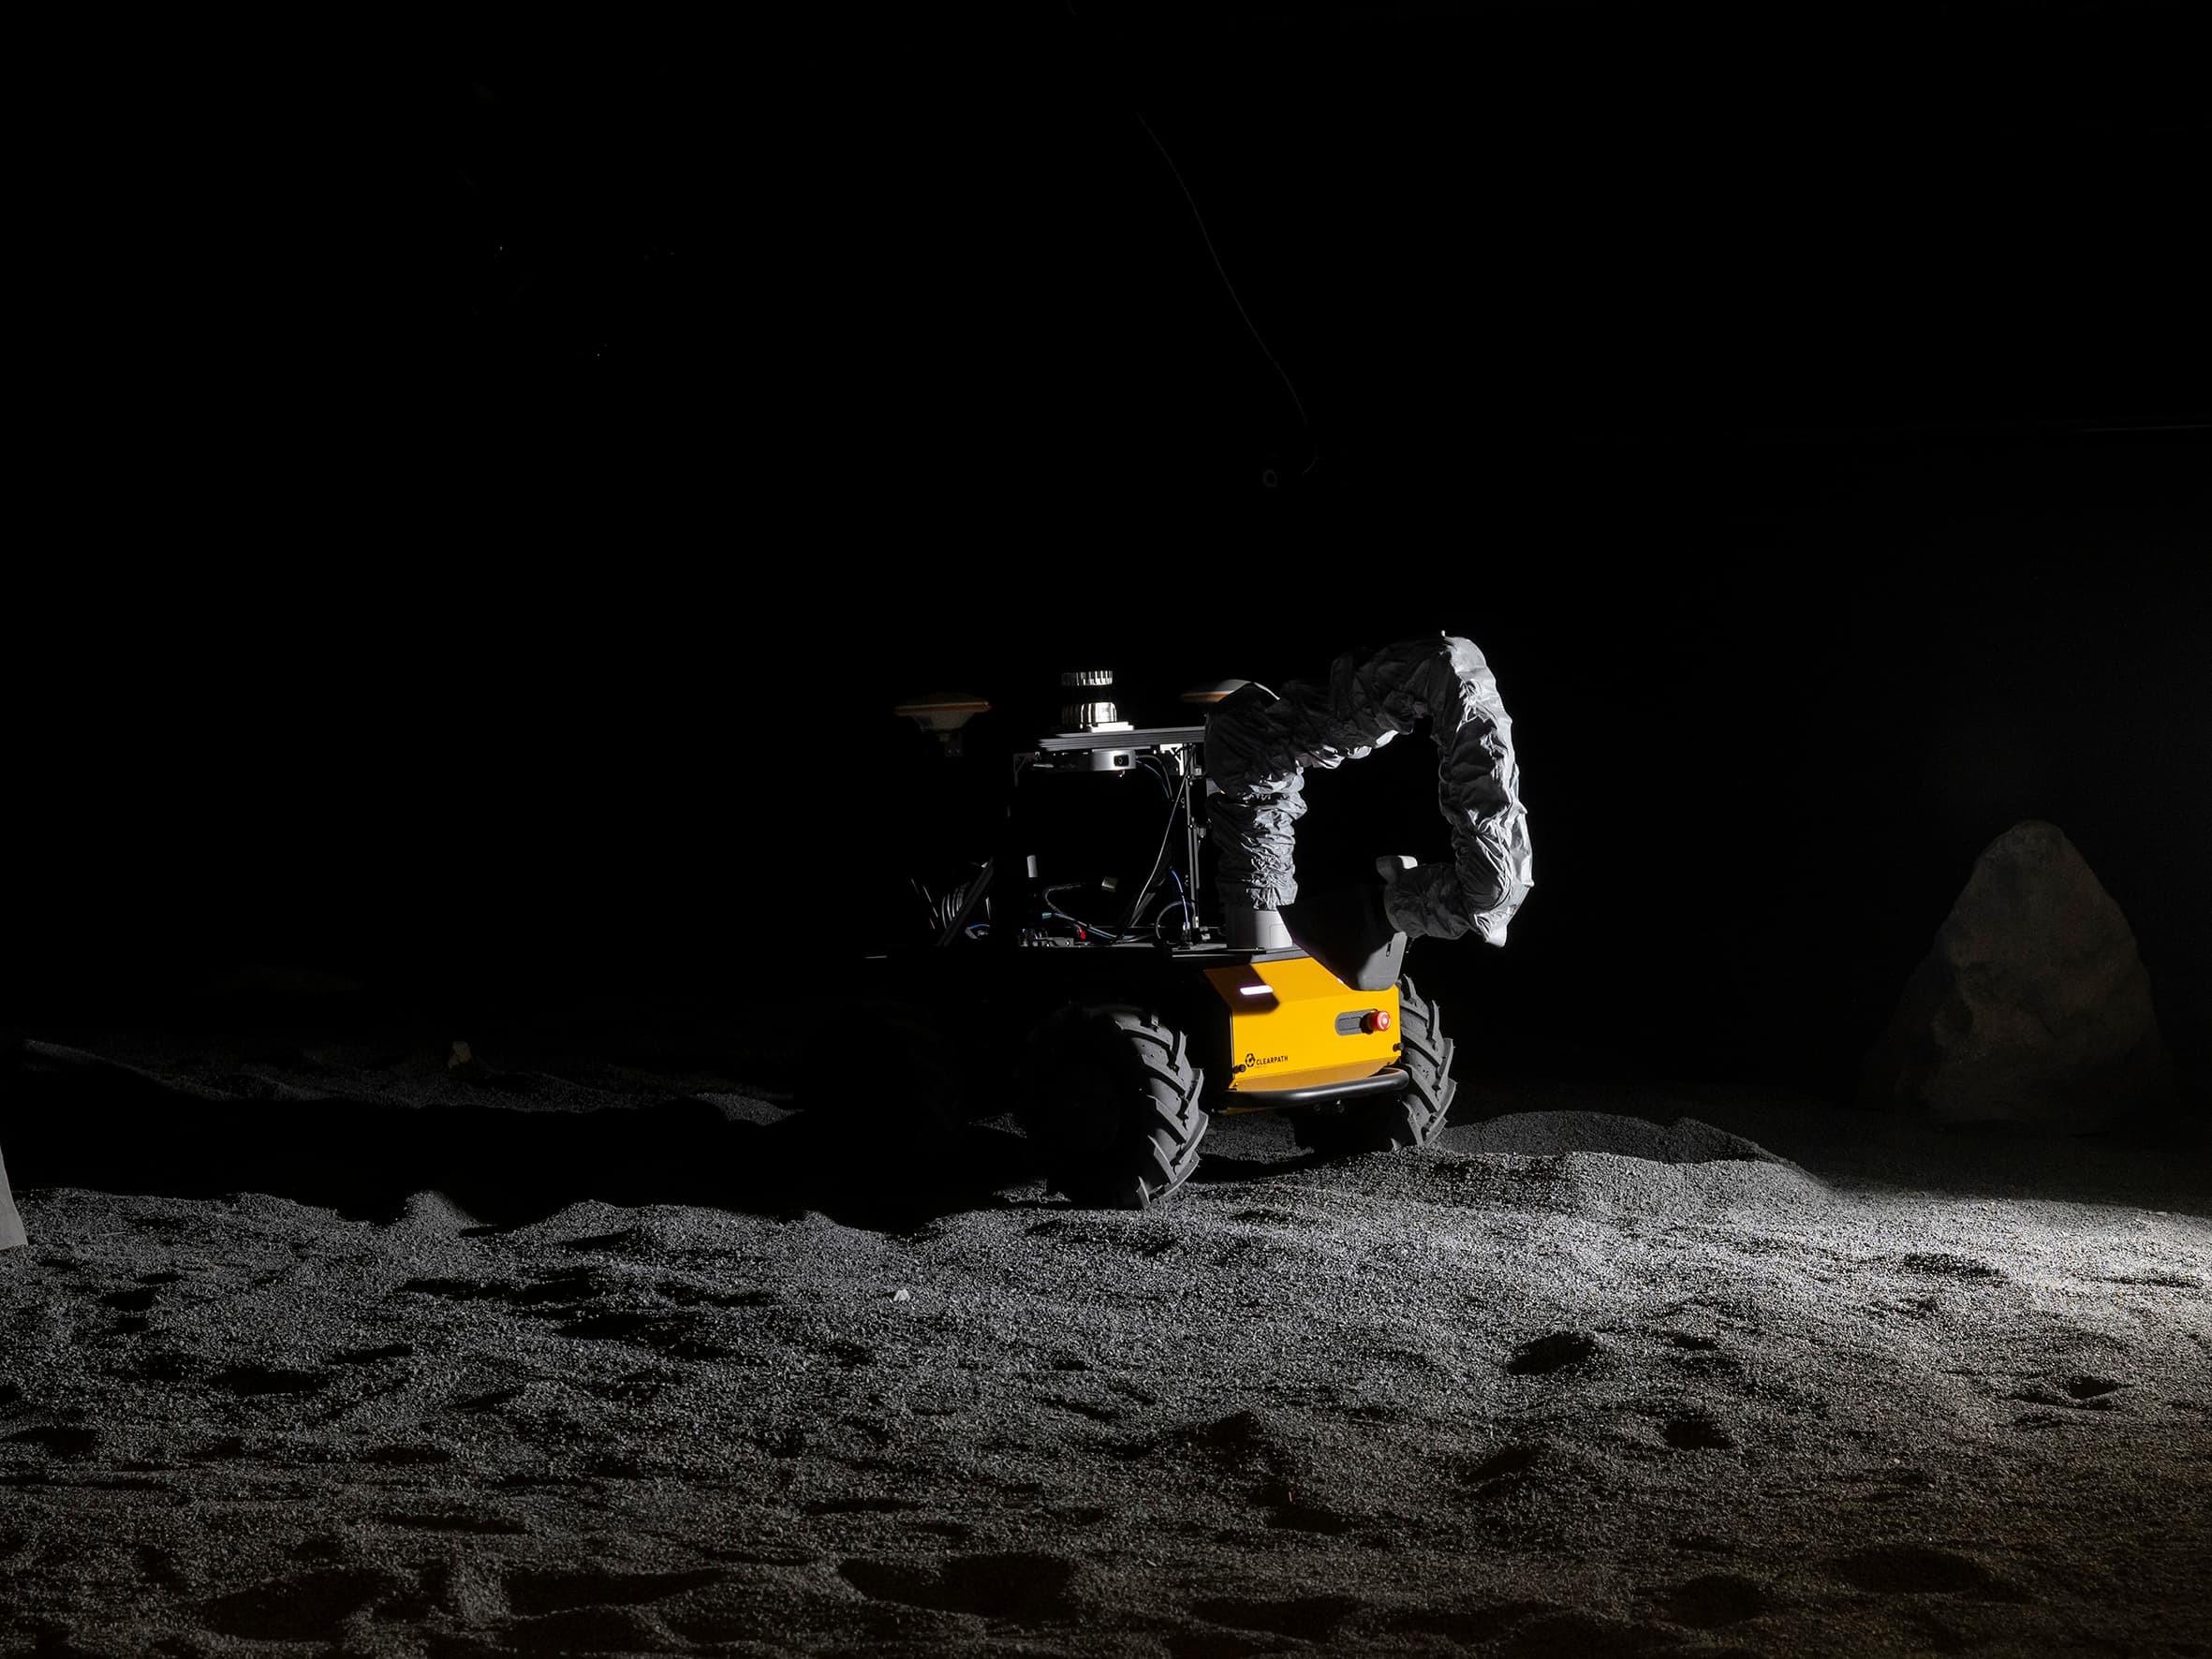
Autonomous navigation, terrain traversal, and sample acquisition for lunar and planetary surfaces — validated in our 100 m² LunaLab analogue facility.
Learn moreOrbital Robotics
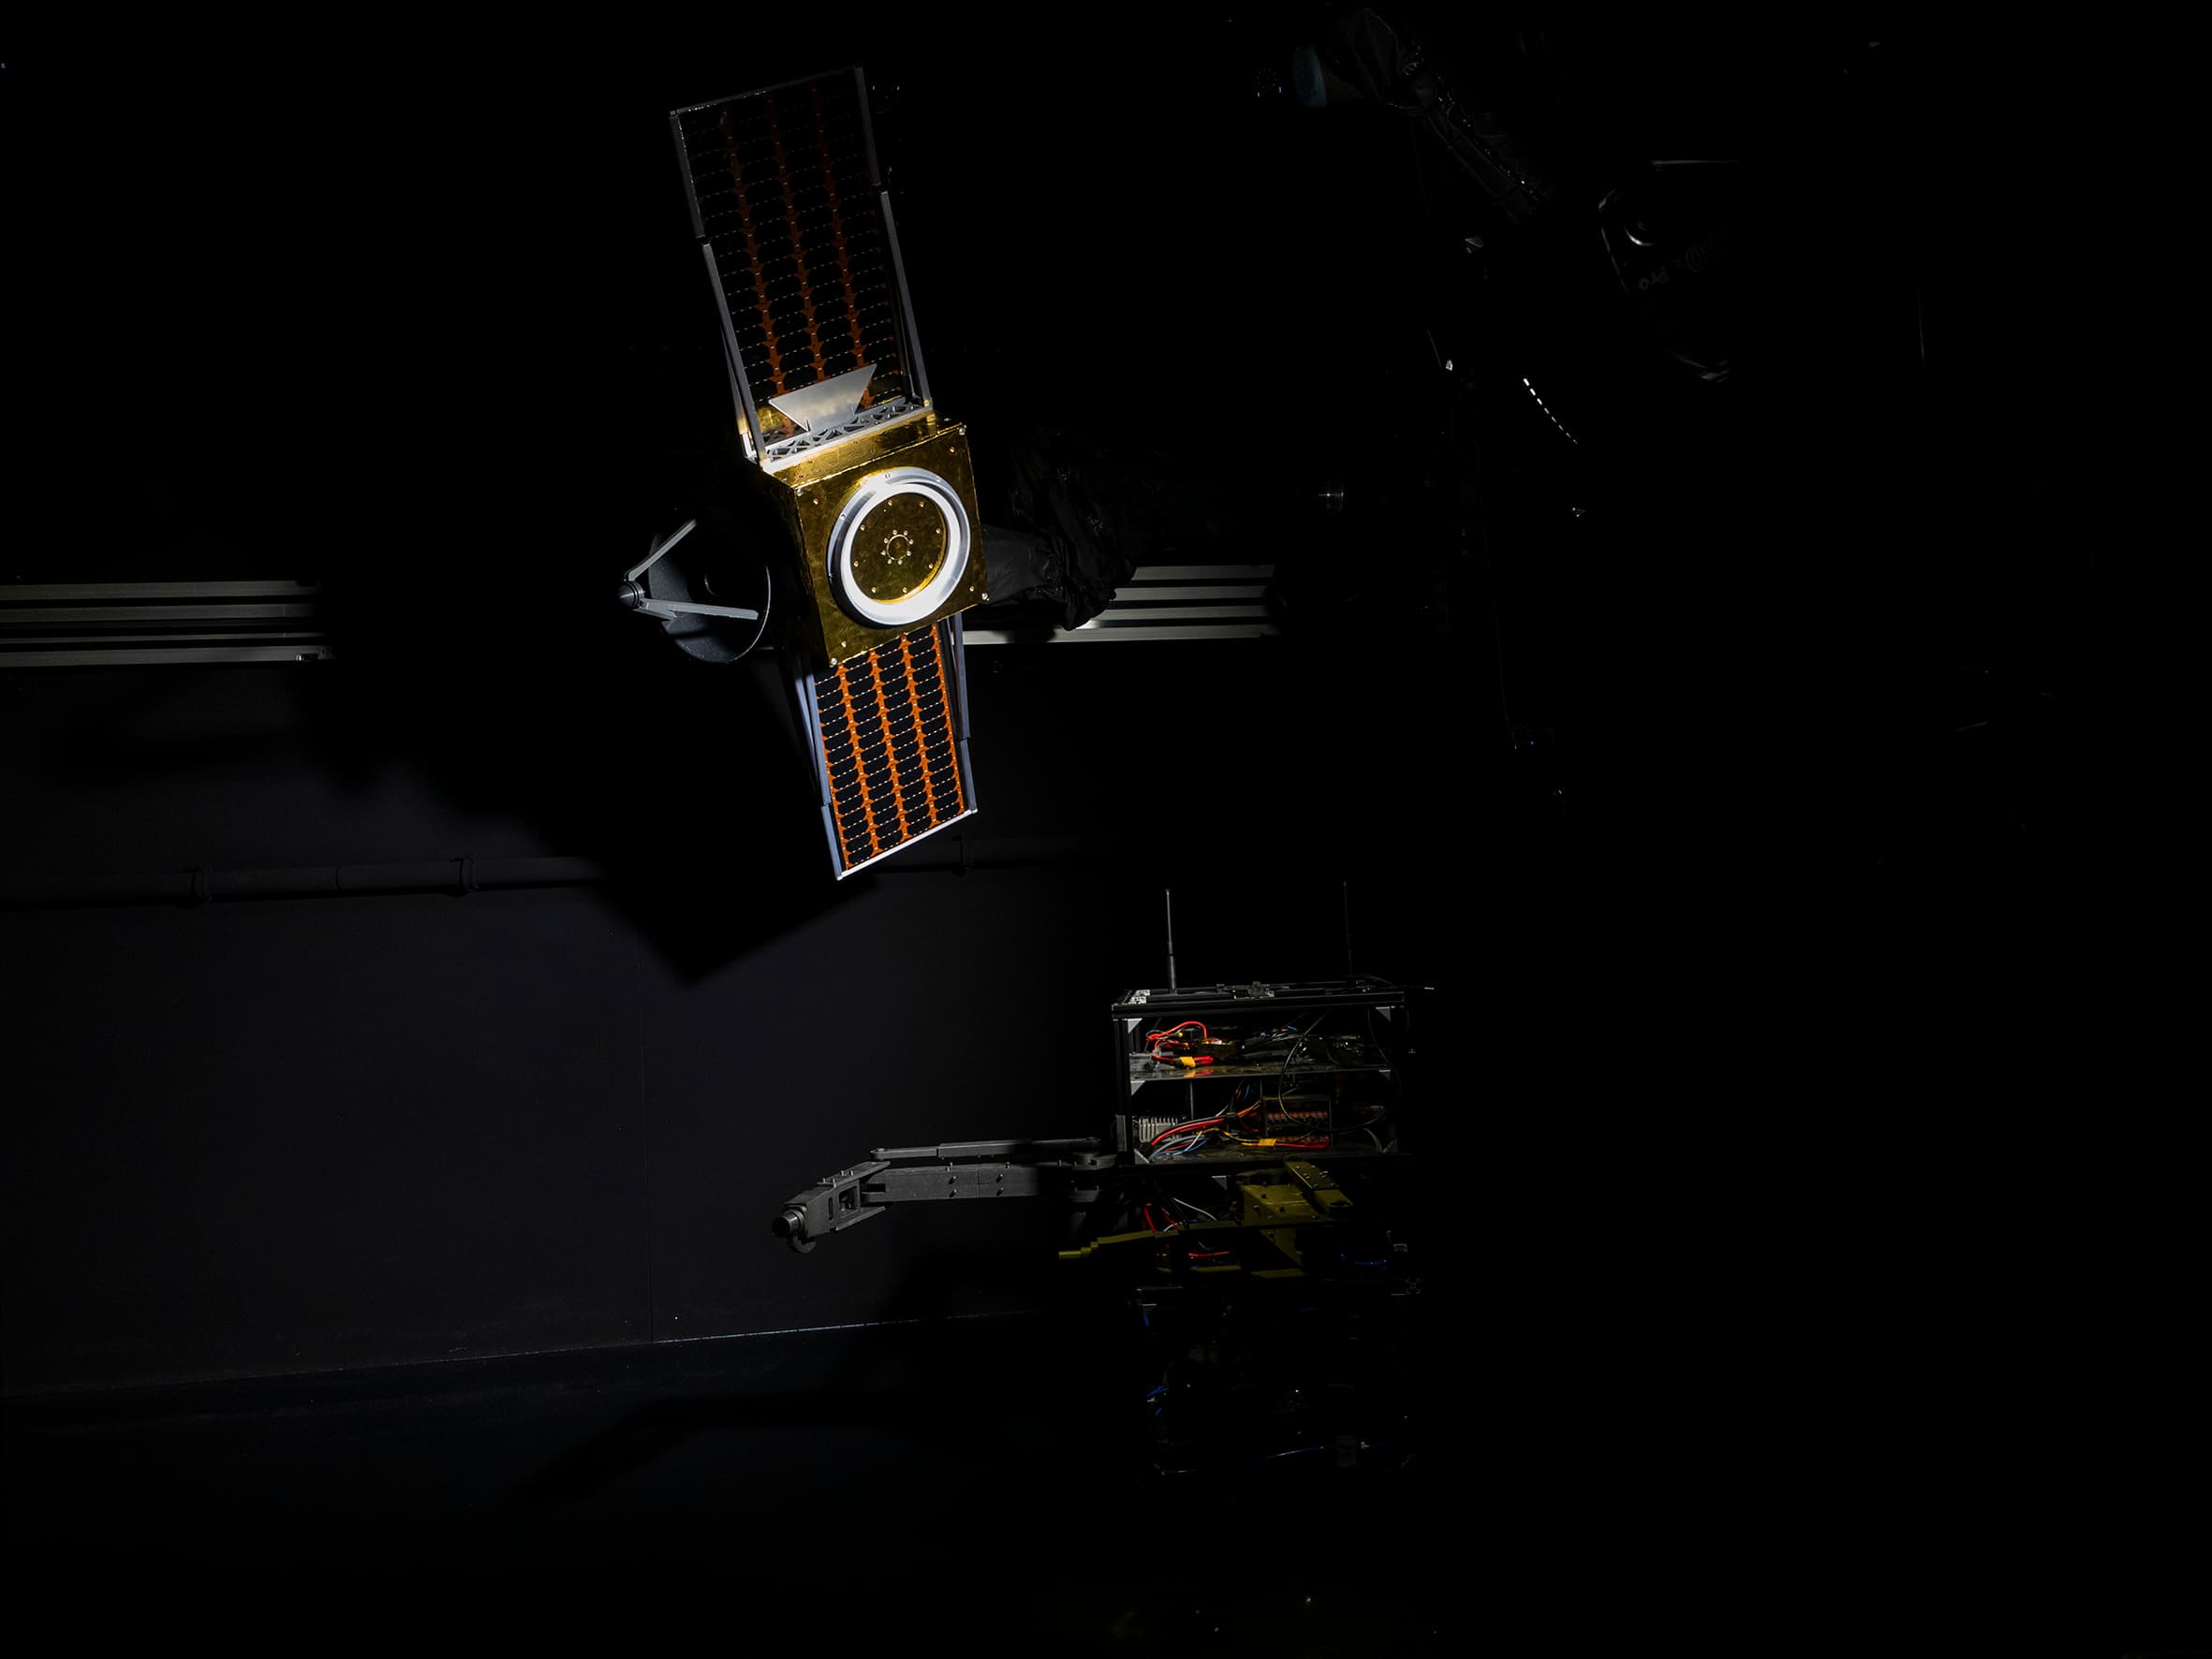
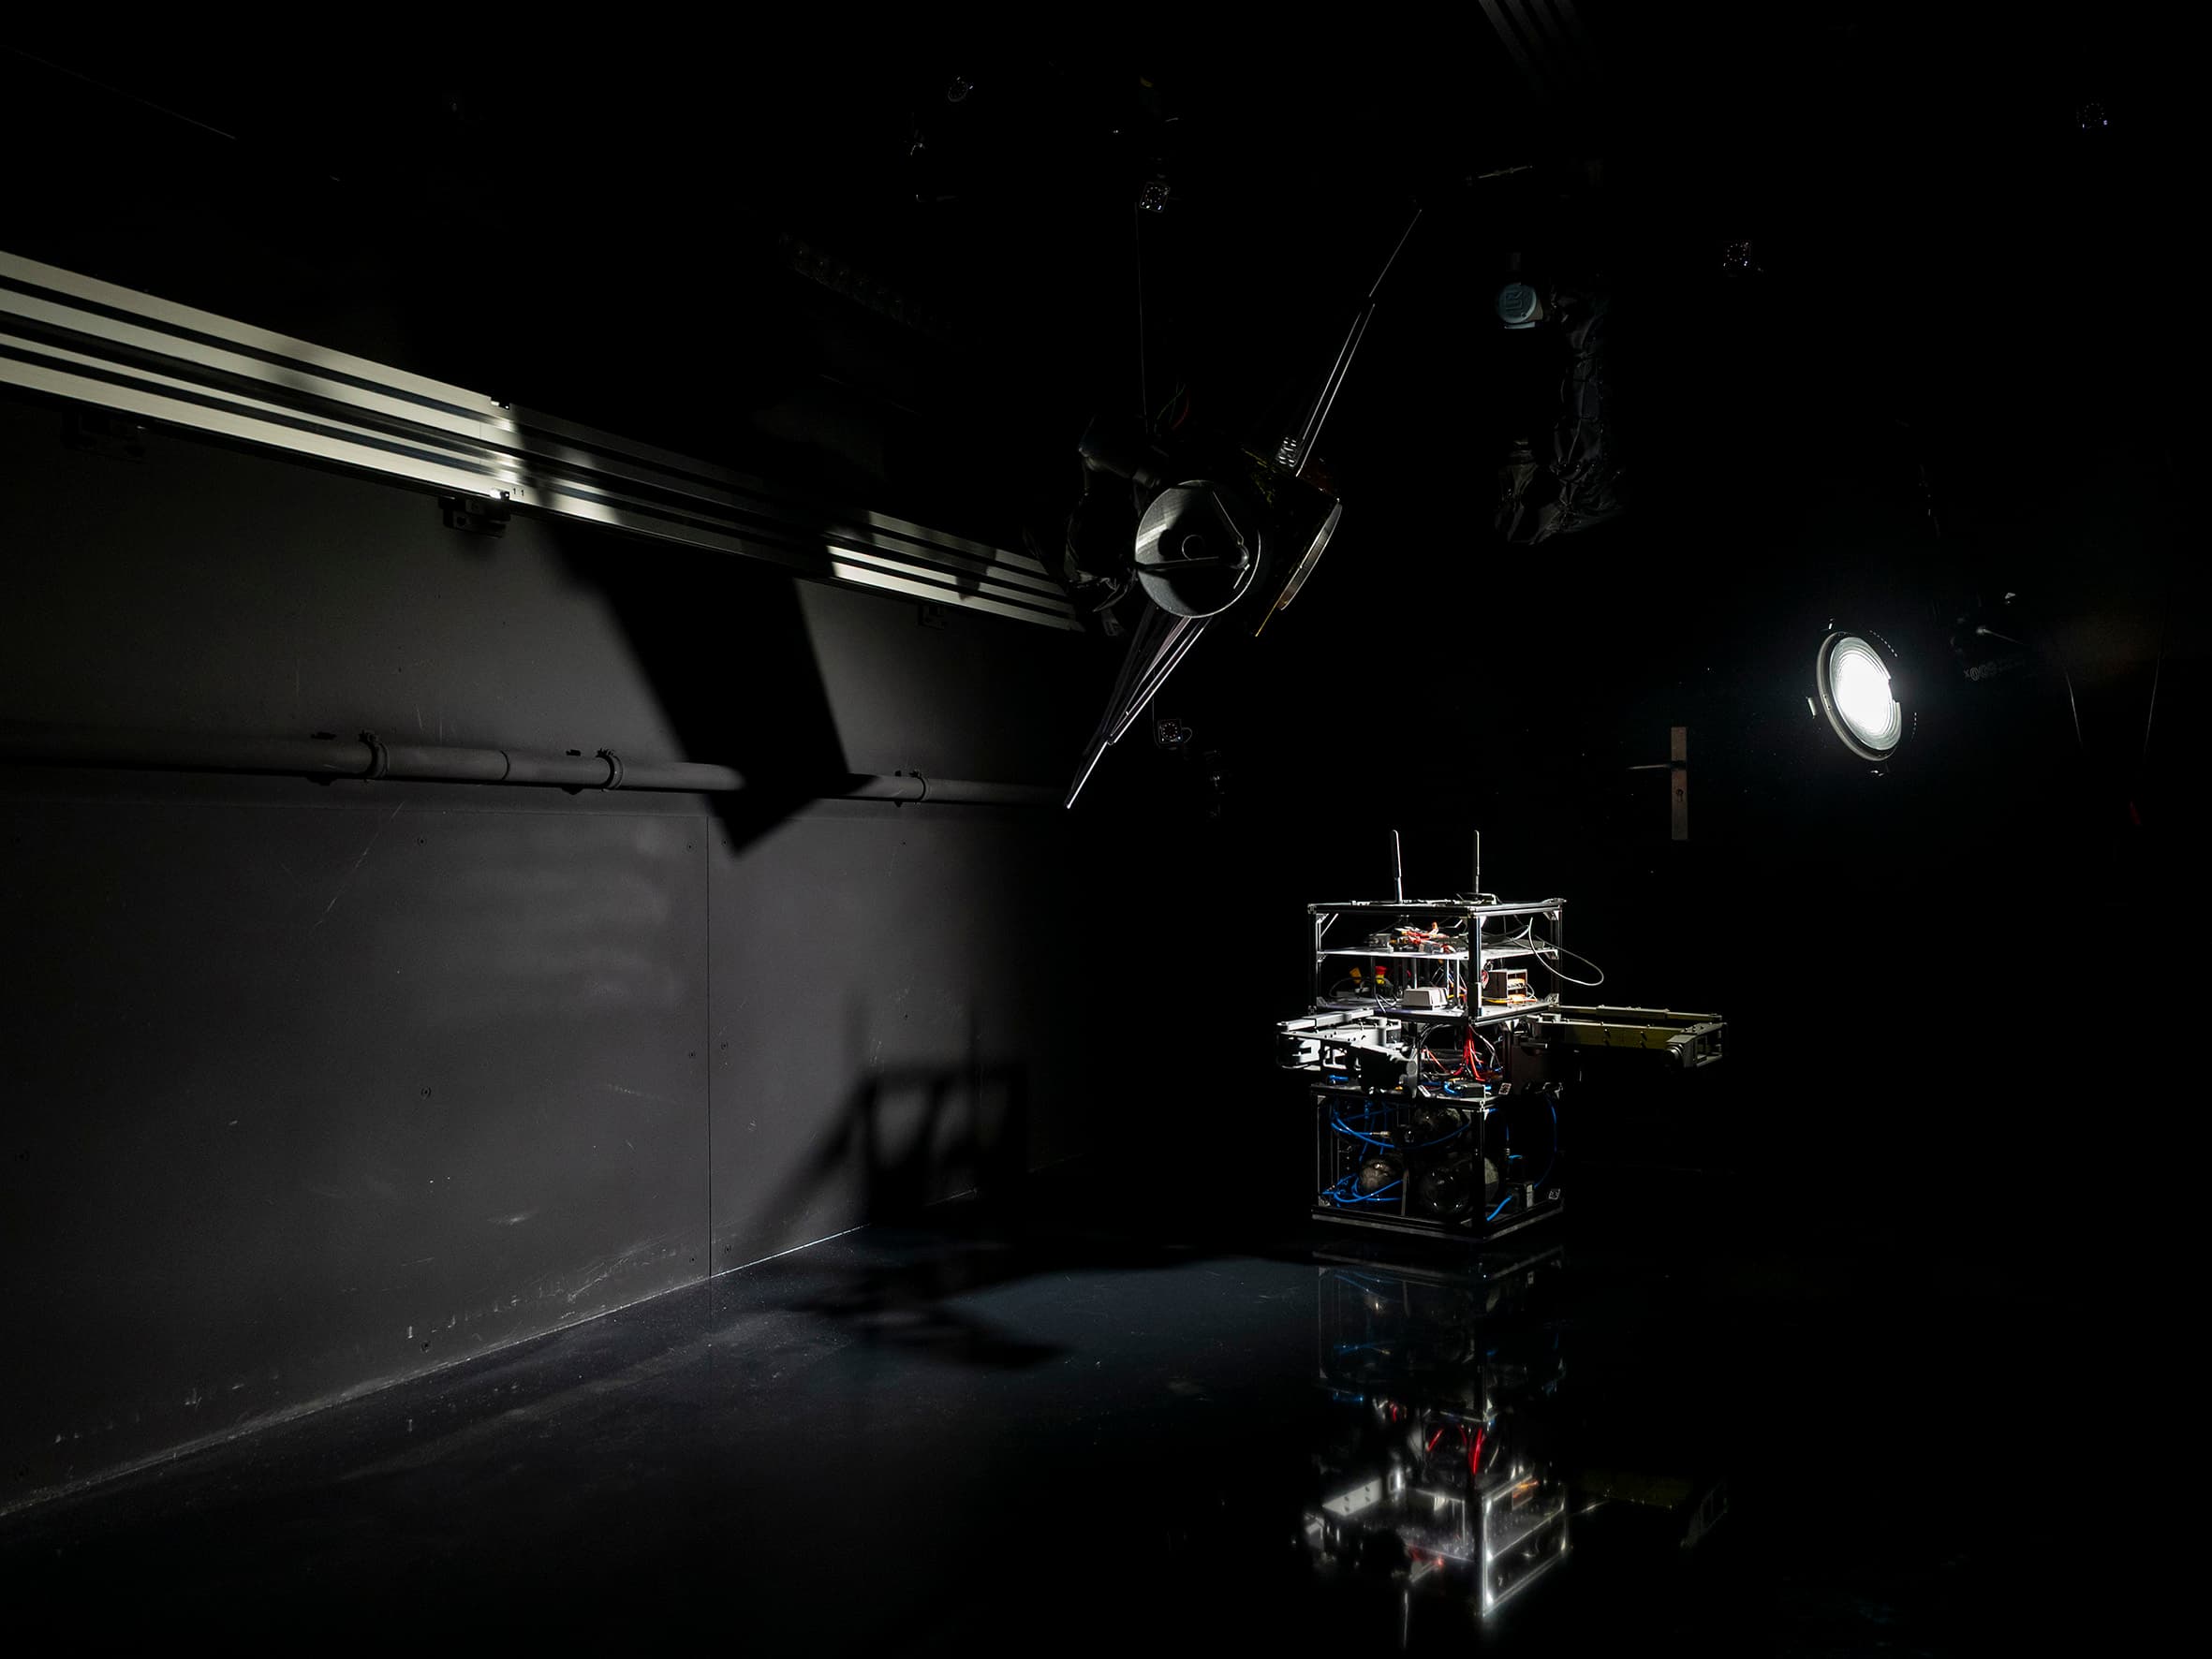
In-orbit servicing, active debris removal, and spacecraft proximity operations — tested using air-bearing platforms in our Zero-G Lab that emulate micro-gravity dynamics.
Learn moreSpace Manipulation
Dexterous robotic arms for on-orbit assembly, inspection, and grasping of uncooperative targets, combining advanced perception with autonomous control.
Learn moreResearch Facilities
Latest Projects
ELYSIUM-XR
Enhanced Lunar Mission Control System for Supervising and Controlling Unmanned Rovers with Extended Reality
Combining collaborative 3D mapping and extended reality to support mission planning and supervisory control of multi-robot exploration at the lunar south pole.
Project DetailsLunarAssembly
Large Time-Delay Teleoperation for Enabling Robotic Assembly on the Moon through Extended Reality and Machine Learning
Enabling Earth-to-Moon robotic assembly despite multi-second communication delays by combining extended reality, delay-robust haptic control, and robot skill learning.
Project DetailsNeverGiveUp
Fallback Adaptable Heterogeneous Multi-Robots for Efficient and Collaborative Lunar Prospection
Developing robust and autonomous heterogeneous robotic systems that can anticipate failures, adapt to challenging lunar terrain, and collaborate efficiently during future lunar exploration missions.
Project Details
